The system
One aircraft. Any deck. Either side of the surface.
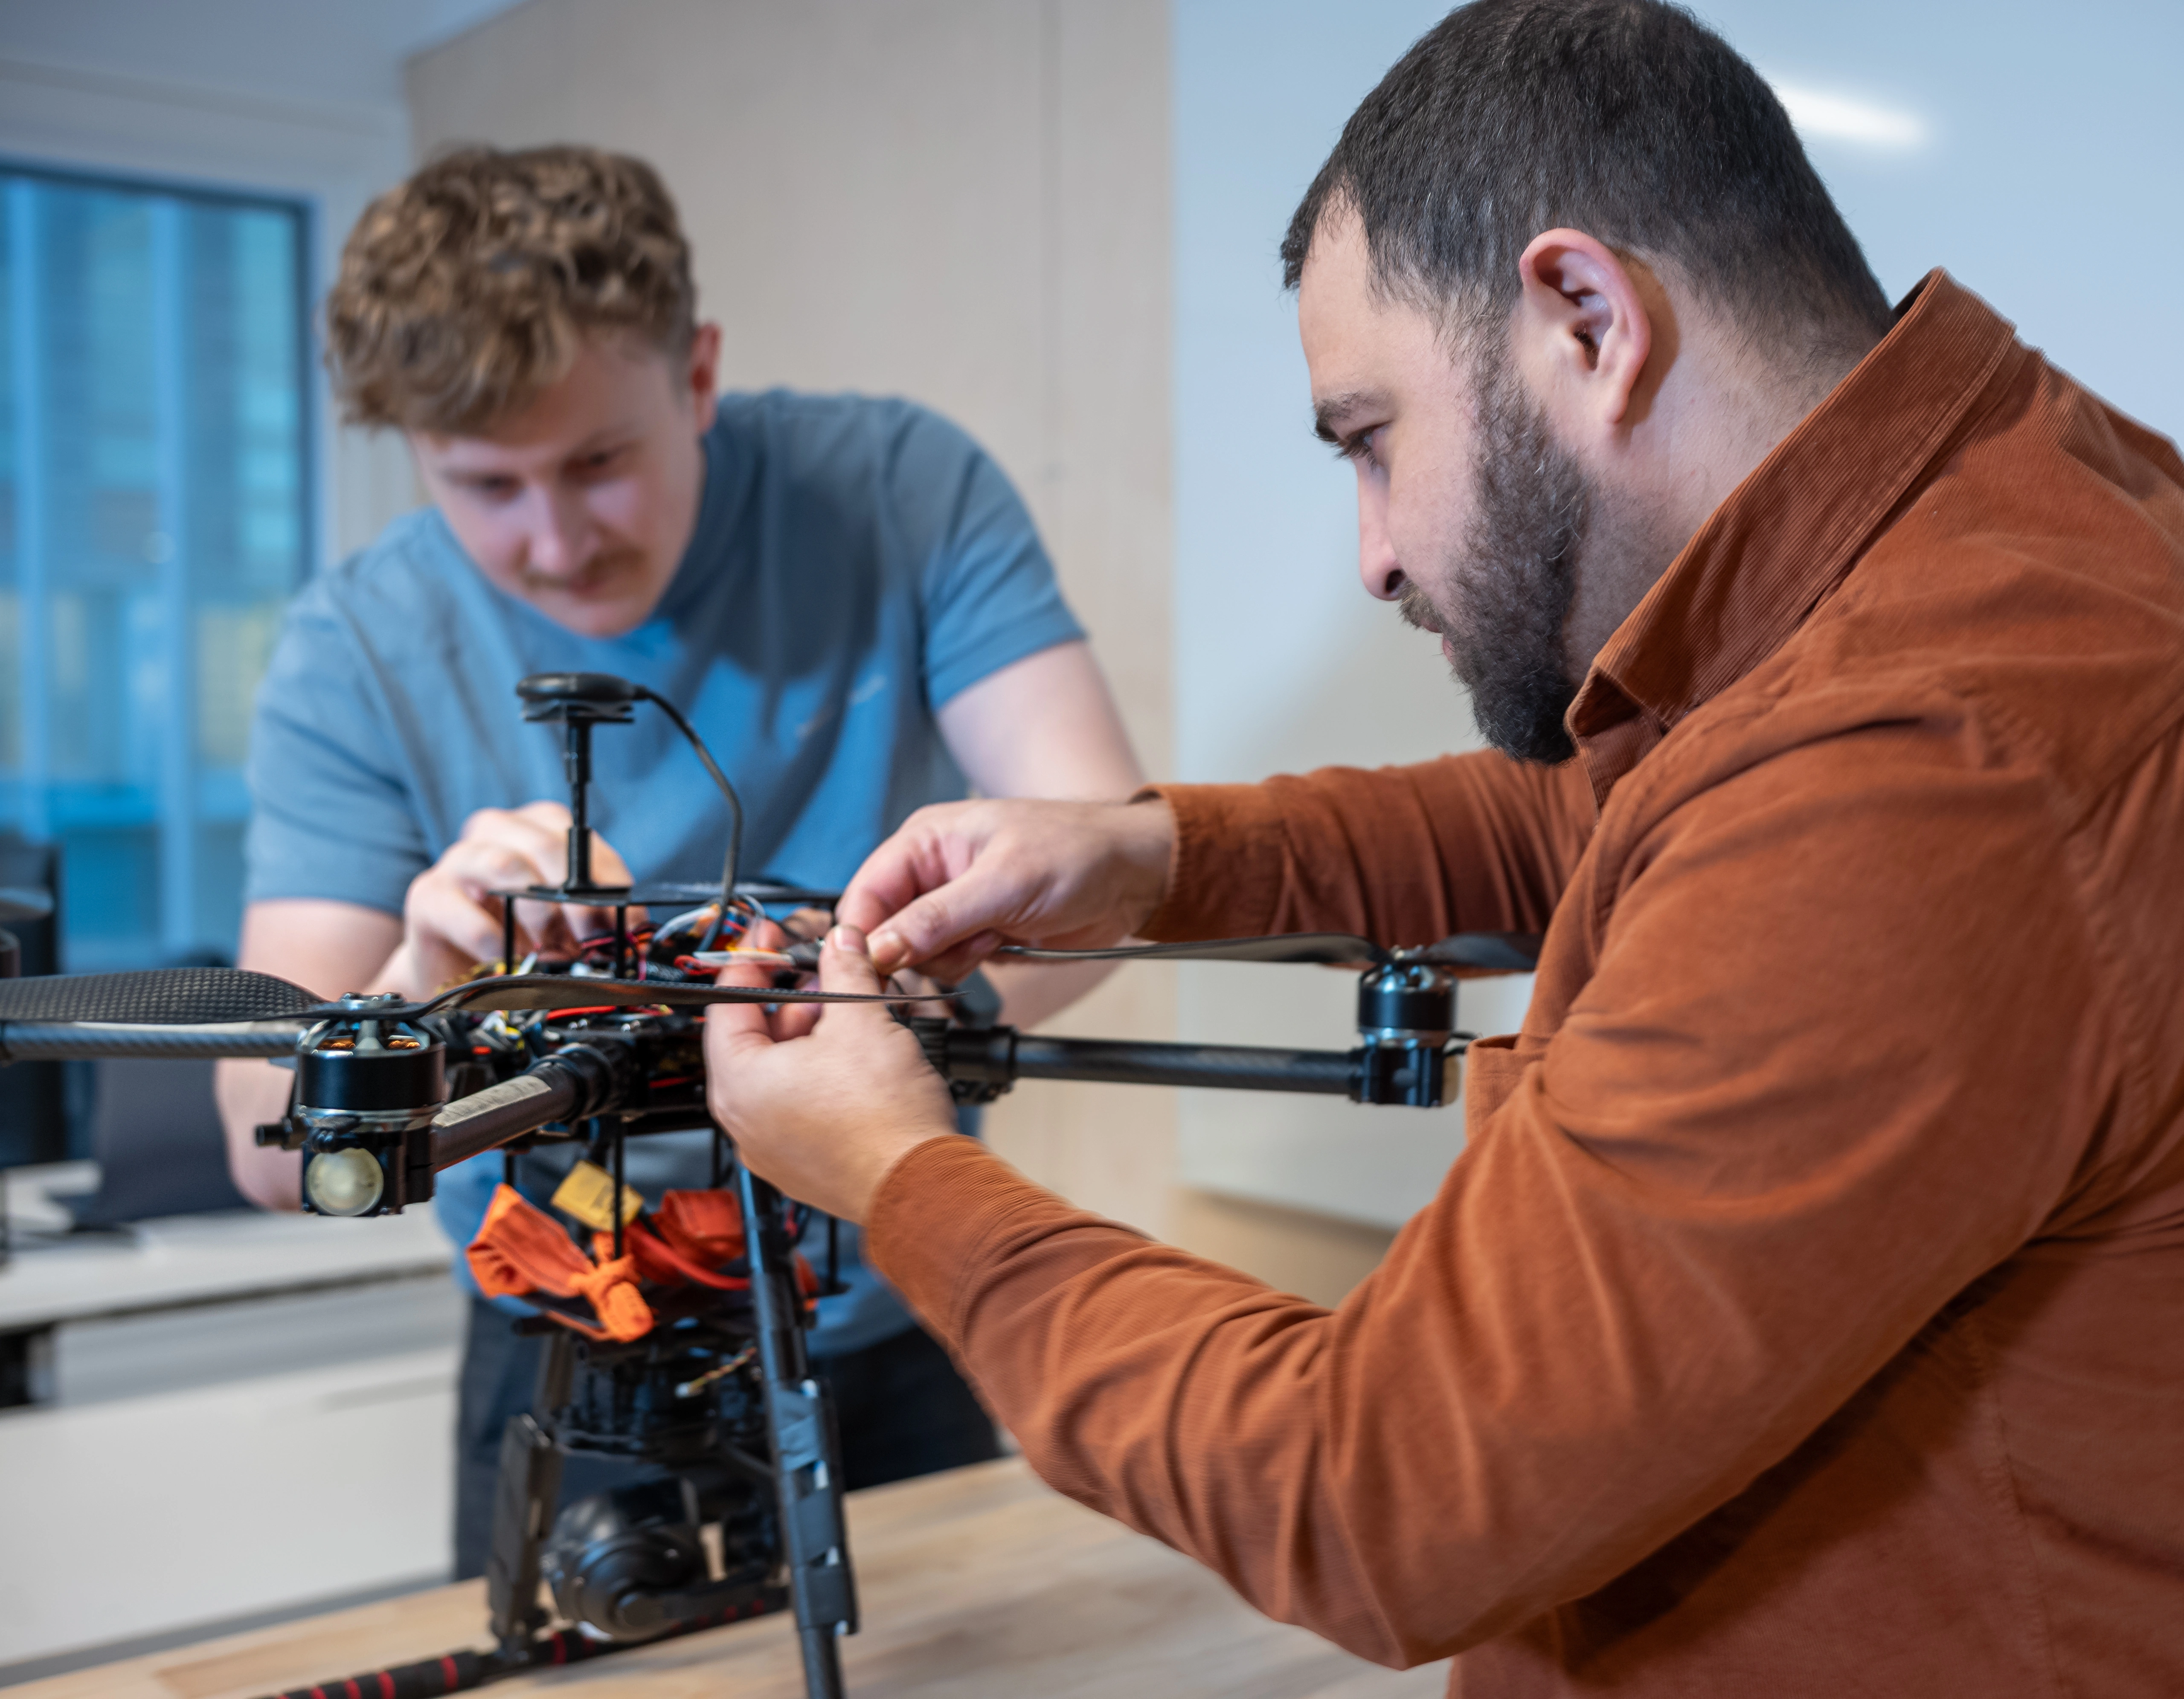
NJORD is a custom-built multirotor for harsh maritime conditions: weather-sealed, autonomous from launch to recovery, and modular in what it carries. The aircraft stays above the surface — the winch takes the payload below it.
Built for the weather that grounds everything else.
Custom-designed to the operation it flies — the deck it leaves from, the sensor it carries, the sea state it comes home in.
- Sealed against the sea
- Spray-, rain- and weather-sealed for deck operations in rough conditions. The aircraft stays in the air — it is the payload that goes into the water.
- Rough-weather recovery
- Autonomous take-off and landing on a moving platform — a vessel rolling, pitching and under way — on RTK-GNSS centimetre positioning.
- Long flight time, low weight
- Endurance to reach the survey point and work it, in electric or hybrid variants to match the operation.
- Autonomy with a switch
- 100 % autonomous flight with the flip of a switch. Manual flights convert to pre-programmed missions in a simple planning interface.
Swap the payload, keep the aircraft.
- 01Winch — lowers sensors beneath the surface
- 02Echosounder — Kongsberg Simrad EK80 split-beam
- 03Camera — daylight spotting and inspection
- 04IR camera — thermal, day or night
- 05Cargo box — light logistics between deck and shore
Fishery
The echosounder into the sea, fifteen nautical miles out — species and size before the set.
Acoustic well monitoring
The winch lowers acoustic sensors to communicate with subsea wells — no divers, no ROV mobilisation.
Surveillance
A rugged, mobile platform with live video streamed to wherever you are, electric or hybrid.
Wind power inspection
Visual and thermal inspection above the waterline, launched and recovered from an offshore service vessel.
R&D platform · In development
Nautilus crosses the waterline.
A submersible UAV designed to fly to the worksite, transition into the sea and operate as an autonomous underwater vehicle. Nautilus is being developed for missions across both environments — including inspection of offshore wind-turbine structures.
Programme facts
- Patents
- EP 3917826 granted · NO/DK/IS · PCT pending
- Research
- SINTEF — AGENT-AI, Horizon EU CHIPS JU
- Variants
- Electric · Hybrid
- Based
- Oslo Science Park, Norway